Application evaluation
Field measurement
Define the measurement you need.
Define the measurement you need.
Evaluate a distance sensor against the accuracy and working conditions of your field instrument. A headline maximum distance alone does not establish suitability for a survey or mapping workflow.
Required accuracy, object reflectivity, object size, visibility and alignment. For LRF3000A1, confirm the separate transmit and reply checksum rules before integration.
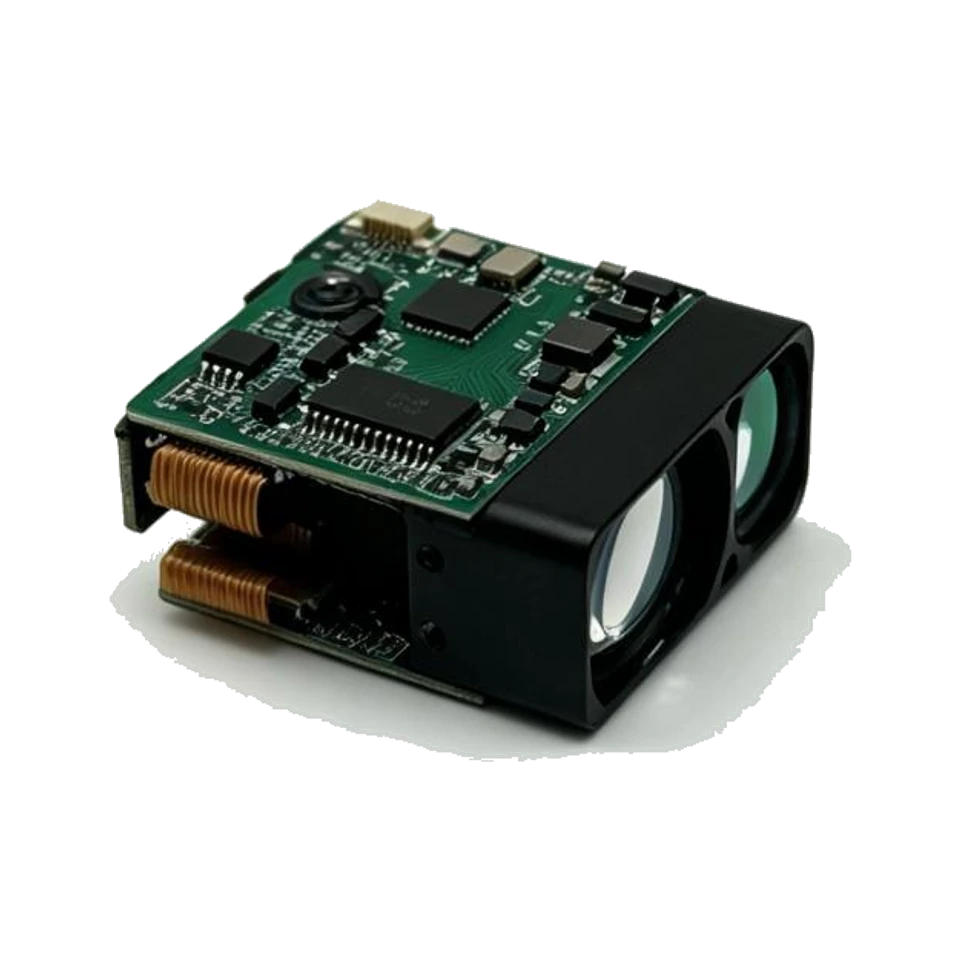 LRF3000A1
Design around the complete system.
Bring the measurement conditions and integration constraints into the same review.
01Accuracy and conditions+
Define the required accuracy, working distance, object reflectivity, object size, visibility and alignment for the field instrument.
02Evaluate the full workflow+
A headline maximum distance alone does not establish suitability for a survey or mapping workflow. Review the model documentation and evaluate with the intended object.
03Transmit and reply checksums+
For LRF3000A1, confirm the separate transmit and reply checksum rules before integration. Do not treat both verification scopes as identical.
From the module to the host.
LRF A series · UART, TTL 3.3 V
Build from the model’s own documentation.
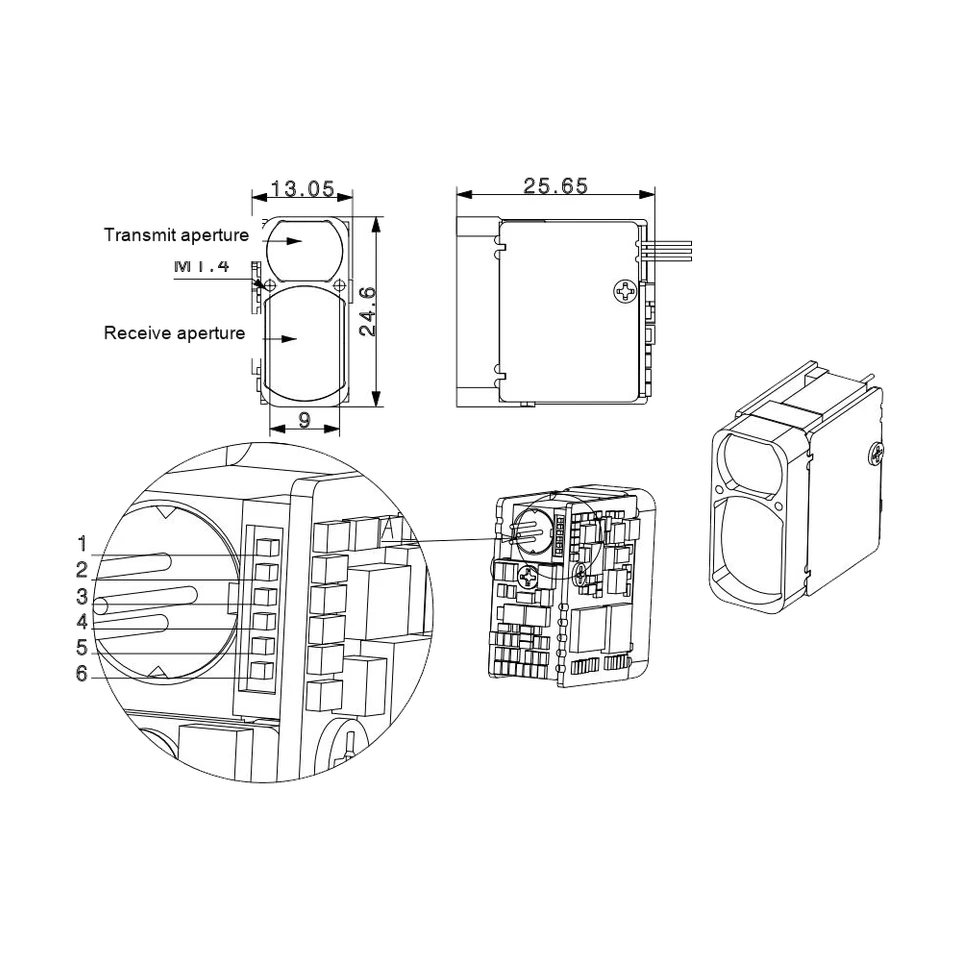
Check the supply, signal levels, pinout and output format for the exact model and revision. Request any missing detail before connecting your hardware.
LRF3000A1Explore other applications.
Bring us the requirement.
Share the distance, object surface, interface, space constraints and quantity. Include a model number if you already have one in mind.
Confirm the current datasheet and laser safety documentation for the specific model and revision. Final suitability depends on your complete device and its operating conditions.