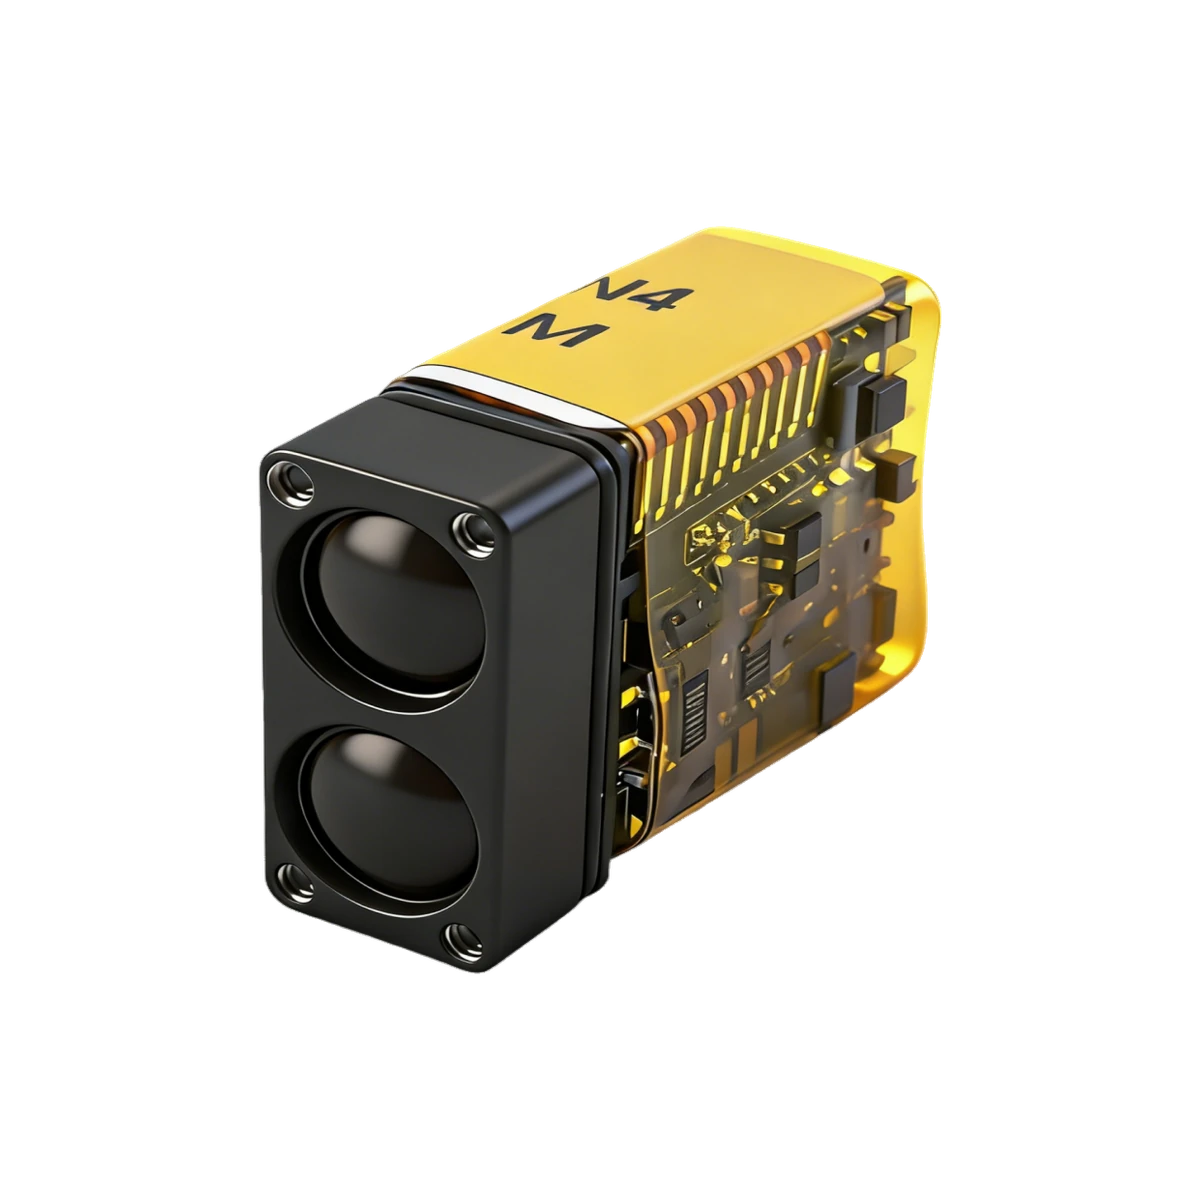
1200 m range class
4–1200 m standard range with a model-specific long-distance accuracy formula.
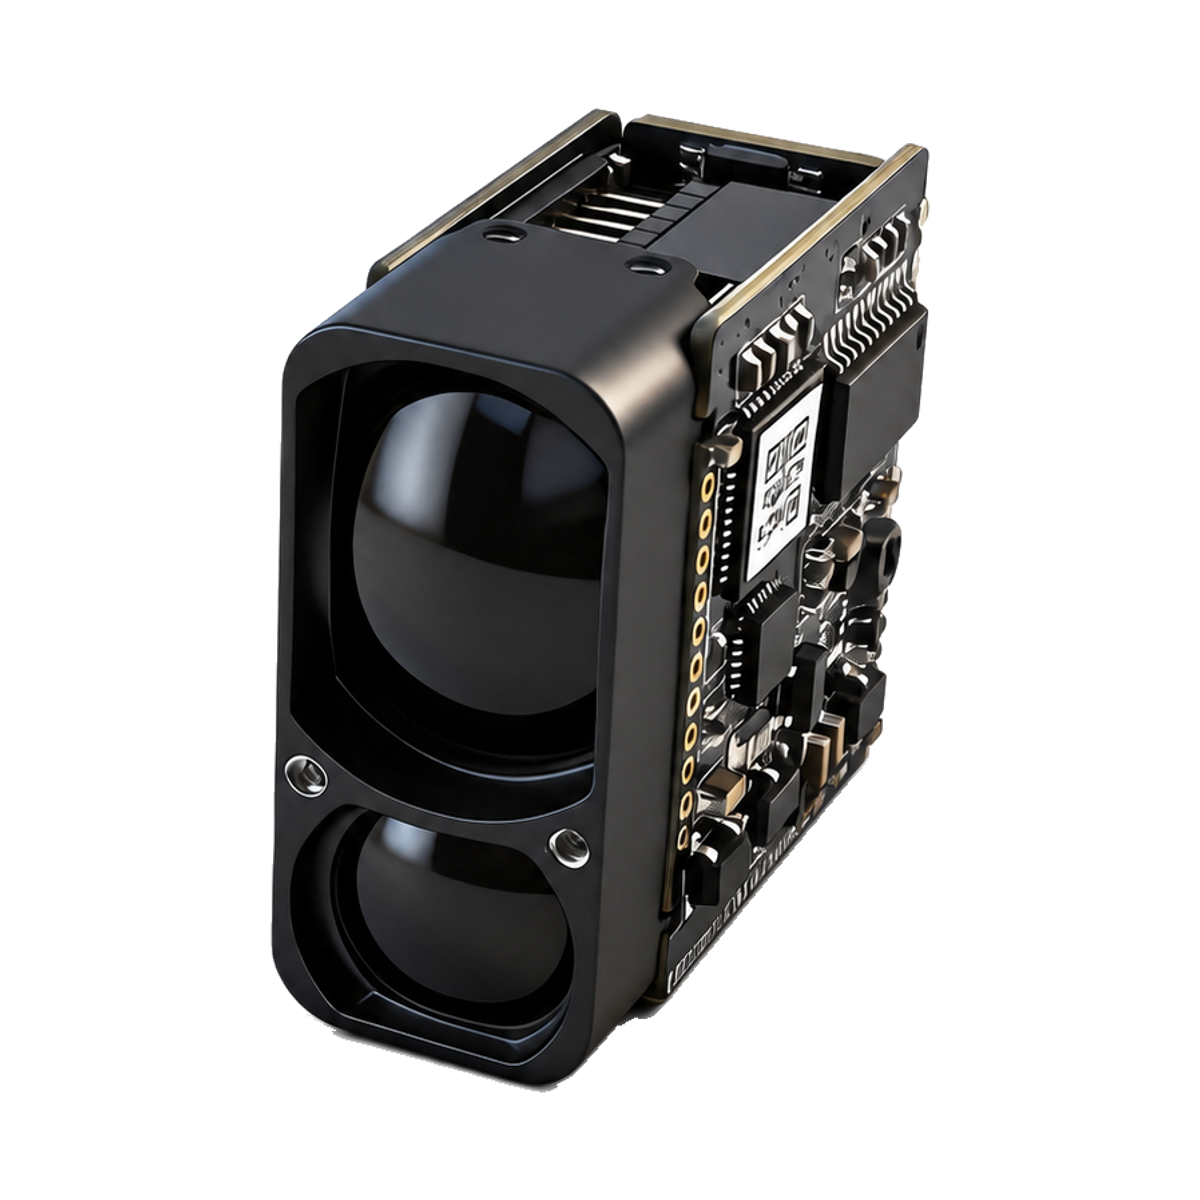
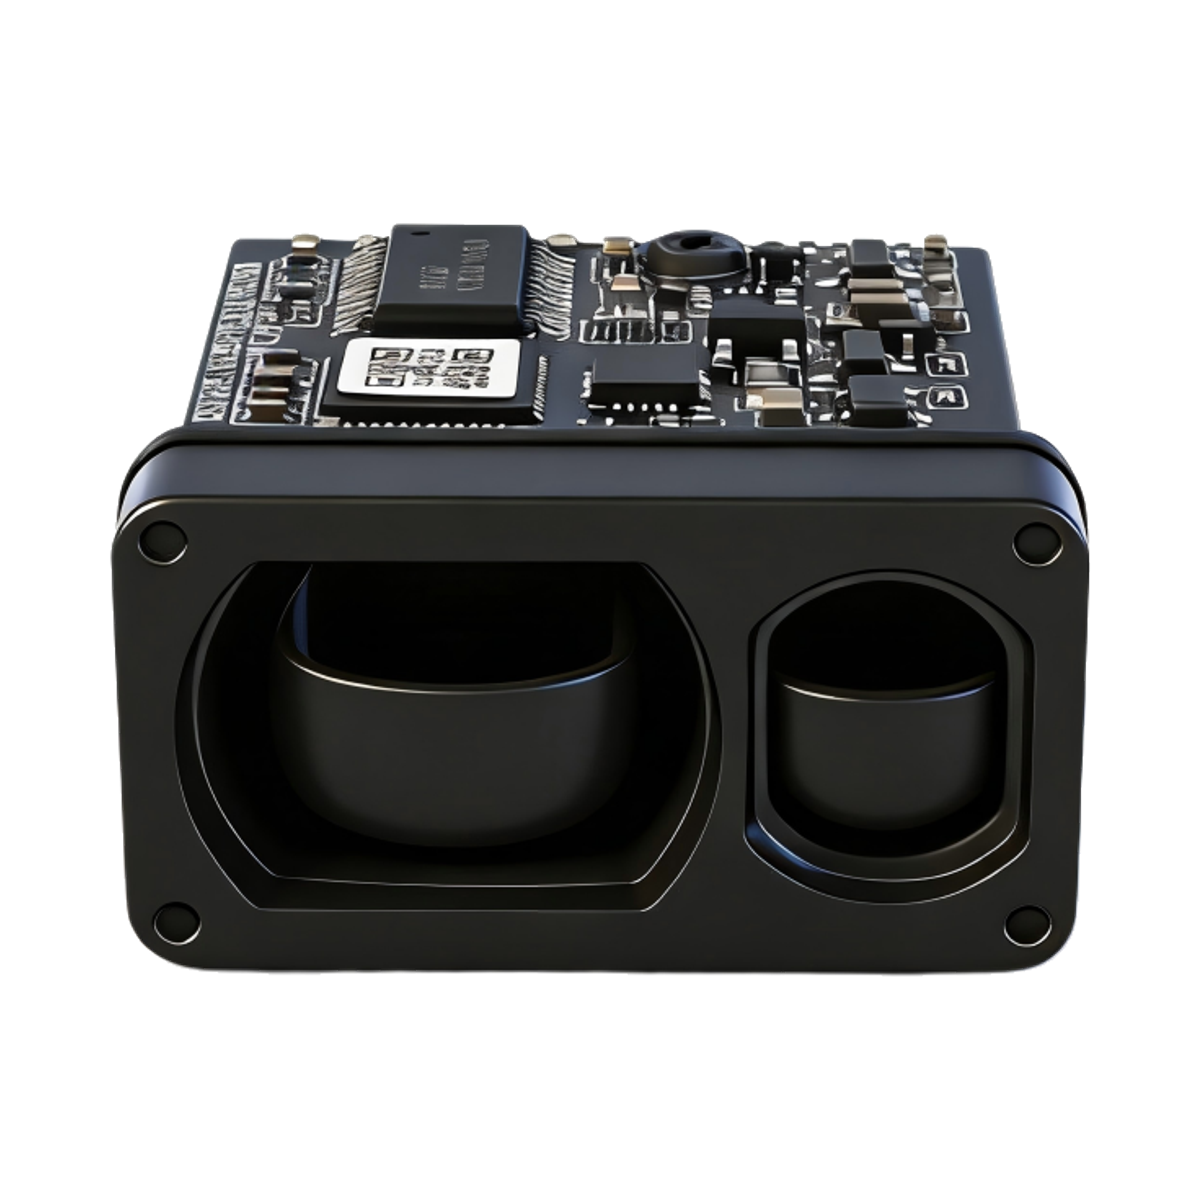
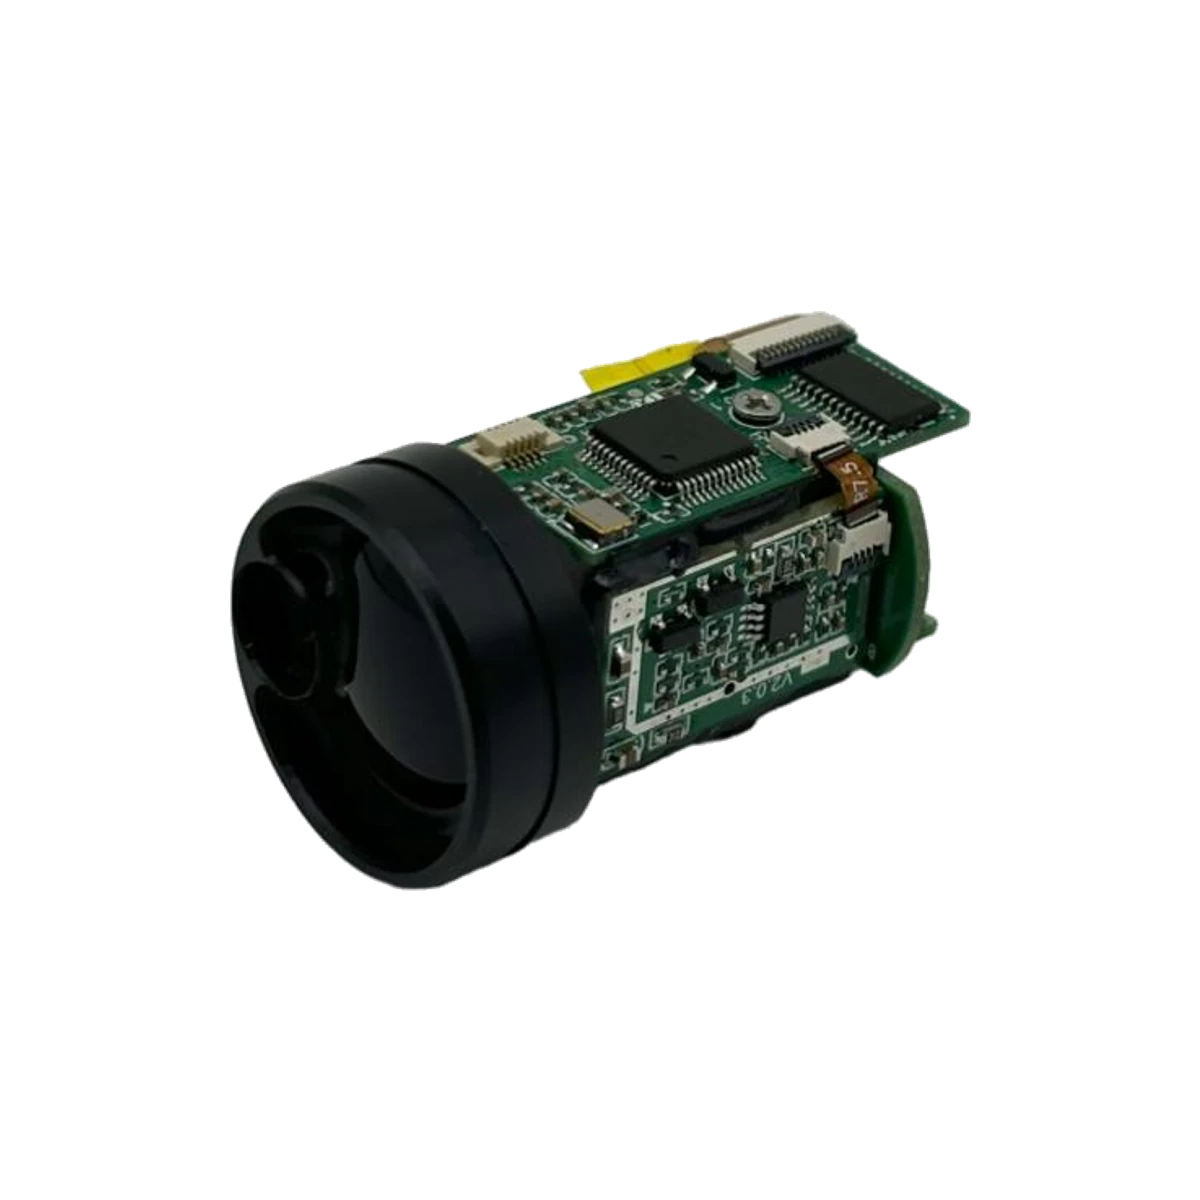
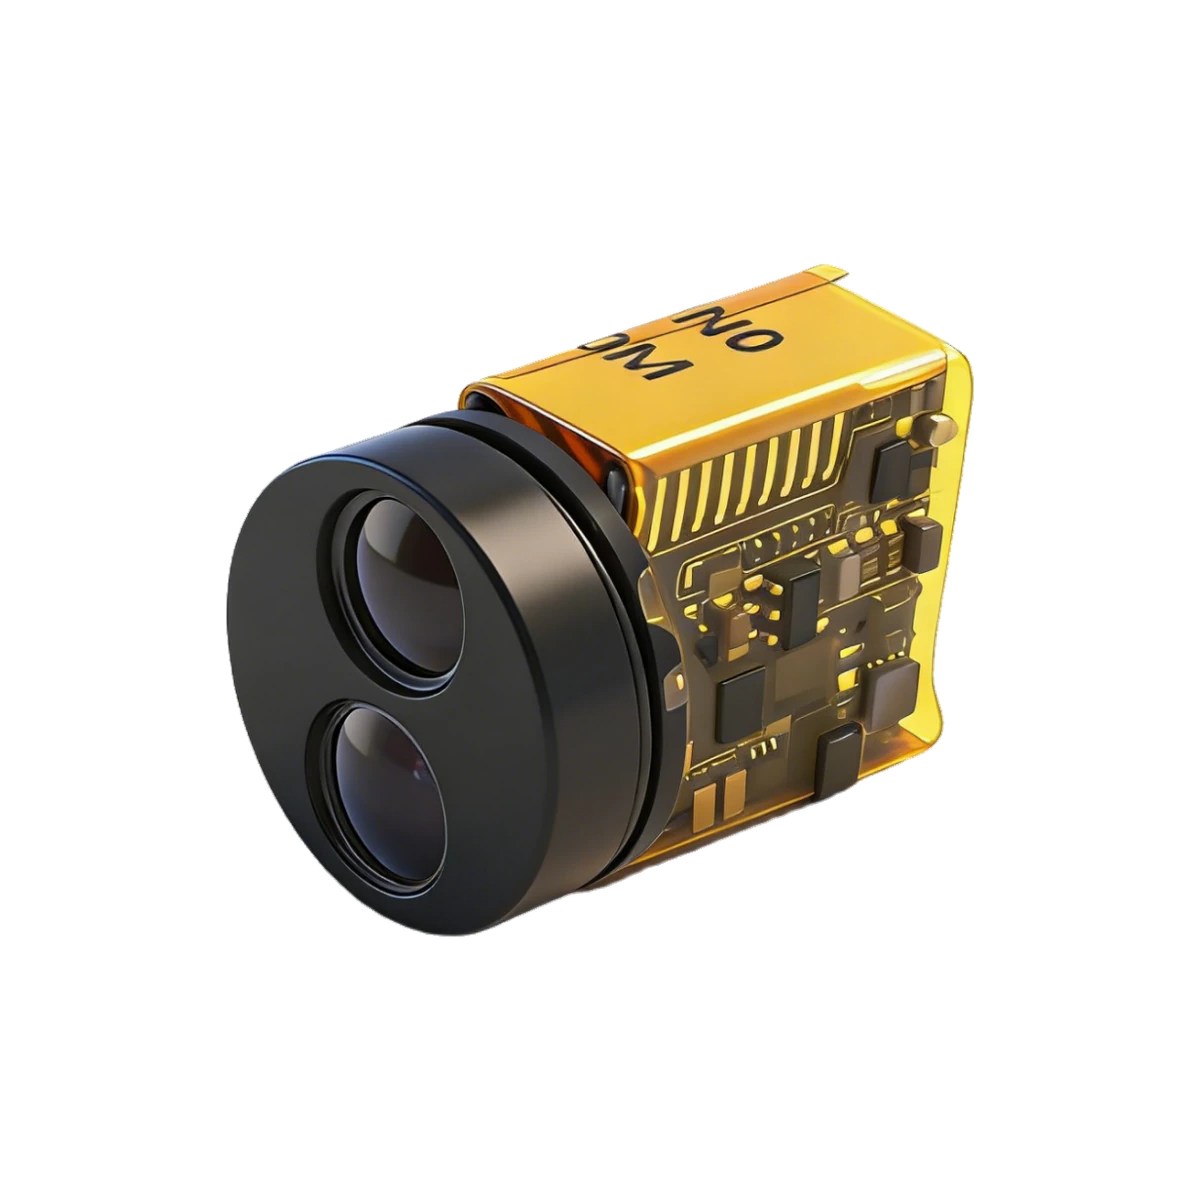
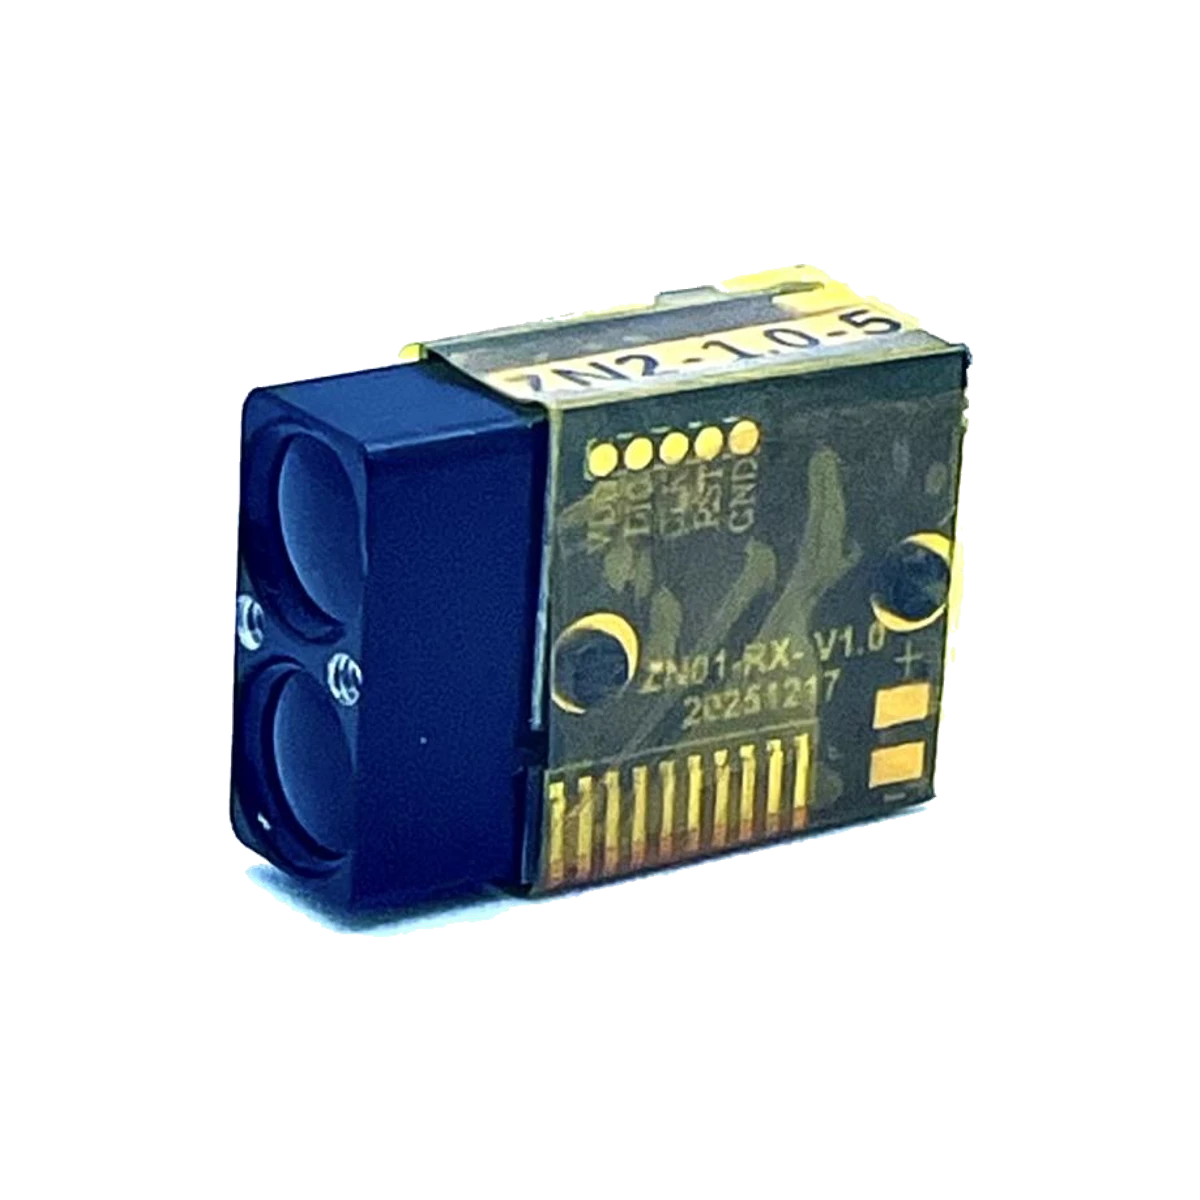
Authentic product views from the ERDI product record. Use the controlled mechanical drawing and connector definition for design release.
Open dedicated 3D viewerOEM laser ranging and photonics module
Product model LR1200E2
LR1200E2 is a compact 905 nm laser ranging module with a 4–1200 m standard measurement range, an adaptive measurement update rate of 2–10 Hz, and UART-TTL communication for OEM integration.
Use the current controlled document revision for design review and confirm the ordered connector and mechanical configuration before release.
Published unit prices apply only to the stated quantity band. Configuration, qualification, tax and Incoterm details are confirmed in the quotation.
The LR1200E2 is a compact ranging module in the E2 mechanical format. It provides digital distance measurements for equipment that needs a ranging subsystem rather than a standalone handheld meter.
Its standard measurement range is 4–1200 m. The accuracy table uses a 500 m breakpoint, with a separate distance-dependent formula for longer measurements. Use the model-specific accuracy formula when setting your system requirements.
The UART-TTL interface supports host-controlled measurements. The manual includes test-software guidance, a six-pin interface definition, and a hexadecimal communication protocol. Use the E2 drawing for packaging and mounting.
4–1200 m standard range with a model-specific long-distance accuracy formula.
2–10 Hz (adaptive); single-shot and continuous measurement modes.
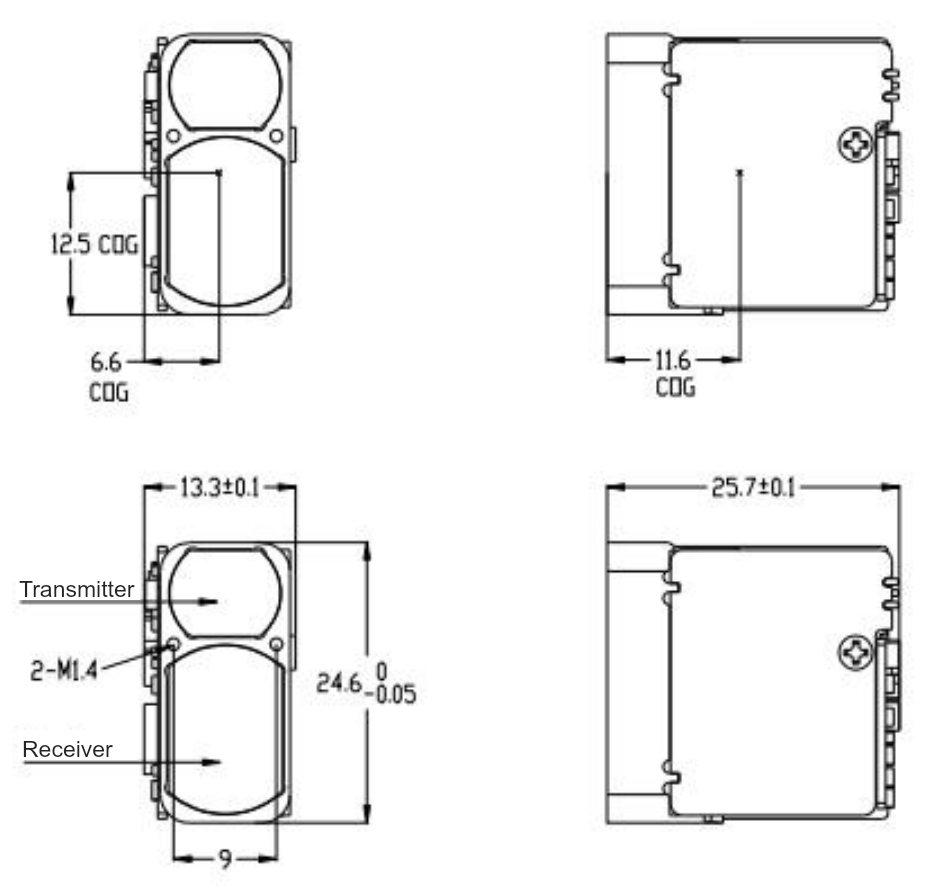
25.7 × 13.3 × 24.6 mm nominal dimensions in the current mechanical drawing; detailed tolerances remain controlling.
115200 bps communication and a 3.3–5 V supply range; use the model-specific pinout and command table.
Read performance values with their target and test conditions. The linked user manual provides the complete mechanical, electrical, and communication details.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Laser wavelength | 905 ± 5 nm | — |
| Measurement range | 4–1200 m | Standard range; actual reach depends on target and environment. |
| Ranging accuracy | ±1 m (6 m ≤ D < 500 m); ±(0.5 + 0.001D) m (500 m ≤ D ≤ 1200 m) | Whiteboard target, 90% reflectivity: 2.3 × 2.3 m for the first distance interval; 2.3 × 4.6 m for the second. |
| Measurement update rate | 2–10 Hz (adaptive) | Completed distance outputs; not the optical pulse-repetition rate. |
| Communication interface | UART-TTL | Custom configurations are specified separately. |
| Baud rate | 115200 bps | — |
| Supply voltage | 3.3–5 V | — |
| Operating temperature | −20 °C to +55 °C | — |
| Storage temperature | −40 °C to +60 °C | — |
| Mechanical drawing dimensions | 25.7 × 13.3 × 24.6 mm | Drawing nominal values. Observe the individual tolerances in the model drawing; do not machine from the rounded summary alone. |
| Weight | ≤10 g | — |
| Ingress protection | IP67 | Lens cavity only; not a blanket rating for the exposed board or the complete host product. |
| Laser safety class | Class 1 | As stated in the model manual; finished-equipment assessment is separate. |
| Laser beam divergence | < 4 mrad (small laser spot) | — |
| Optical material | Resin aspheric lens | — |
| Receiver aperture | 9.2 mm × 14.5 mm | — |
| Startup time | ≤ 200 ms | — |
| Inrush current | ≈ 350 mA | Approximate value in the specification table. |
| Sleep power consumption | < 1 mW | — |
| Standby power consumption | ≈ 0.2 W | Approximate value in the specification table. |
| Short-range power consumption | ≈ 0.4 W | Approximate value in the specification table. |
| Operating power consumption | ≈ 1 W | Approximate value in the specification table. |
Single-shot mode requests one reported distance. For a weak return, the manual describes repeated internal measurements before reporting stable distance data. Continuous mode produces repeated results at the documented adaptive update rate.
The standard measurement-rate specification is 2–10 Hz (adaptive). Higher-rate custom versions mentioned in the manual are separate configurations, not the default performance of a standard unit.
| Pin | Signal | Function |
|---|---|---|
| 1 | GND | Power ground |
| 2 | VCC | Power input |
| 3 | I/O (Reserved) | Reserved for expansion |
| 4 | TXD | Transmit data: module → host |
| 5 | RXD | Receive data: host → module |
| 6 | SW-SHOT | Function-enable input. The required control polarity must match the supplied configuration. |
Use the drawing and its tolerances for installation. This drawing is reproduced directly from the current LR1200E2 user manual.
The following explains the general measurement principle of a 905 nm pulsed ranging system with APD reception. A short near-infrared pulse travels to the target, and reflected light returns through the receiving optics to a silicon avalanche photodiode (APD). The receiver converts the optical return into an electrical signal for distance measurement. Individual circuit implementations and performance remain model-specific.
Transmit pulse → target → reflected light
Receiving optics → APD → timing processing → host
A 1 m change in distance corresponds to about 6.67 ns of round-trip travel time in free space. This is a physical relationship, not a claim about the module’s timing resolution or measurement accuracy. [1]
A silicon APD provides internal avalanche gain before subsequent signal processing. This can help a receiver detect weak optical pulses, but the gain also brings excess noise. More gain is not always better: receiver bandwidth, background light, bias stability, and temperature all affect the usable signal-to-noise ratio. [2] [3] [8]
A large, bright surface usually returns more usable light than a small, dark, or angled one. At long distances, beam spreading can place only part of the transmitted light on the intended target. The receiver also sees losses through the atmosphere and any protective window, so a maximum range rating must be read with its target conditions. [1] [4] [7]
Narrowband optical filtering reduces unwanted background light while passing the laser return. Lower transmitter wavelength drift helps preserve this overlap as temperature changes. Filter bandwidth, incidence angle, component variation, and temperature must still be considered together; a narrow filter alone does not establish sunlight immunity. [5] [6] [7]
Noise changes the estimated arrival time of a return pulse. A fixed-threshold detector can also trigger at different times as pulse amplitude changes, an effect called timing walk. The complete receiver and timing chain determines the final measurement error—not the detector response time by itself. [1] [8] [12]
The E2 and E4 families cover 1000, 1200, 1500, and 2000 m nominal range classes. LRF1200A1 and LRF3000A1 have their own electrical, mechanical, and measurement specifications. Equal range-class numbers do not make different families pin-compatible or mechanically interchangeable.
Start with the smallest and darkest target your application must measure, the required update rate, and the available installation space. Then compare the model-specific supply, interface, drawing, and long-range accuracy formula. Do not select only by the maximum range number.
Validate the complete installation with representative targets, lighting, temperature, and the final protective window.
Use 4–1200 m as the standard measurement range, and evaluate it against the target you actually need to measure. Nighttime or customized figures in supporting material are conditional cases, not a replacement for the standard range.
±1 m (6 m ≤ D < 500 m); ±(0.5 + 0.001D) m (500 m ≤ D ≤ 1200 m). D is the measured distance in meters. Whiteboard target, 90% reflectivity: 2.3 × 2.3 m for the first distance interval; 2.3 × 4.6 m for the second. At 1000 m, the long-distance formula evaluates to ±1.5 m. The stated accuracy intervals begin at 6 m, even though the measurement range begins at 4 m.
No interchangeability should be assumed from a shared range class. The E2 drawing shows 25.7 × 13.3 × 24.6 mm nominal dimensions. Compare overall envelope, mounting details, optical alignment, connector position, and tolerances before reusing an installation.
No. UART-TTL refers to logic-level signals, not the electrical signaling of RS-232 or RS-485. Use an appropriate interface converter where required and confirm the ordered module’s signal levels. The supply-voltage range is not a specification for the UART input-voltage tolerance.
Distance depends on the strength of the accepted return. Reflectance, illuminated target area, viewing angle, and beam spreading all matter. A dark object can absorb more of the pulse, while a small object may intercept only part of the beam. A range quoted for a large white target or building is not a guarantee for clothing, vegetation, wires, or other small targets. [4]
Background sunlight adds optical noise; fog, rain, and airborne particles can attenuate the target return and produce scattered light. Spectral filtering helps reject out-of-band background, but does not remove all of these effects. Test the final system in the required visibility and lighting conditions, with clean optics and the intended protective window. [5] [7] [9]
Accuracy describes agreement with a reference value under stated conditions. Resolution is the smallest change that produces a perceptible change in the indication. Repeatability describes measurement precision under stated repeatability conditions. A fine output increment does not establish equally fine accuracy, and stable repeated readings can still contain a systematic offset. [10] [12]
The APD converts received light into an electrical signal and provides internal multiplication. It also introduces excess noise, and its gain depends on bias and temperature. The useful operating point is a balance between signal gain, noise, bandwidth, and stability. APD gain is a receiver design parameter, not a user-adjustable shortcut to greater range. [2] [3] [8]
No. Laser-pulse repetition rate describes the optical pulse sequence; measurement update rate describes completed distance outputs. A measurement may use multiple pulses, signal qualification, and processing. Use the measurement-rate specification for the ordered model and firmware rather than a component-level pulse rate. [12]
Temperature can shift the transmitter wavelength and output, and it can change APD gain, excess-noise factor, dark current, and front-end noise. A low-wavelength-drift transmitter helps maintain spectral overlap with the receiver filter, but it does not eliminate all temperature effects. Use the module operating-temperature rating and validate the assembled system over its required temperature range. [2] [6] [7]
Yes, as part of an evaluated optical integration. Check transmission and coatings near 905 nm, clear aperture, angle, thickness, surface quality, and contamination. Window transmission and filter response can change with incidence angle, while unwanted surface reflections can reduce optical margin or add stray light. Validate with the final window installed rather than assuming a bare-module test is sufficient. [7]
No. Read the laser-class statement in the model manual, then assess the accessible emission of the finished equipment under the applicable requirements. Added optics, drive or control changes, and service access can affect the assessment. Neither wavelength nor a bare component rating alone establishes the final system classification. [11]
Provide minimum and maximum distance, target size and material, required accuracy and update rate, ambient light and weather, temperature range, available power, host-interface levels, installation dimensions, protective-window design, and expected quantity. These inputs allow a model-specific recommendation and a representative acceptance test.
The model manual defines product specifications. The references below explain measurement principles and integration effects; results from other systems are not LR1200E2 performance ratings.
Technical inquiry
Share the target, range, interface and expected quantity. Your selected model stays attached to the inquiry.
Same series
Open a nearby model to compare range, SWaP and interface choices.