SPAD-based pulsed ranging
905 ± 5 nm direct time-of-flight ranging with single-photon reception for weak optical returns.
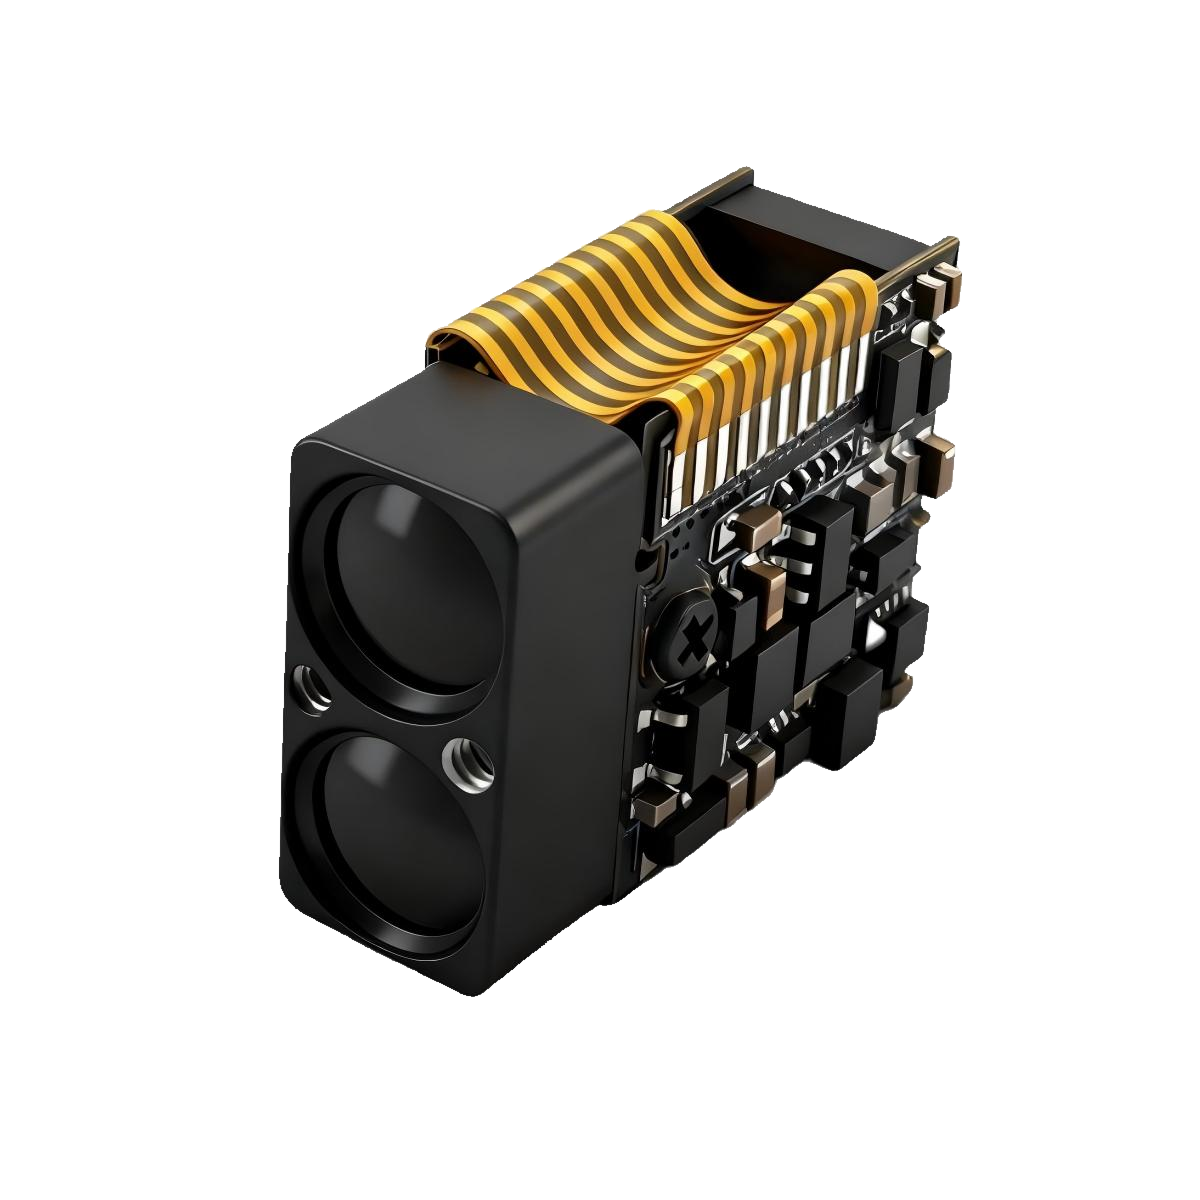
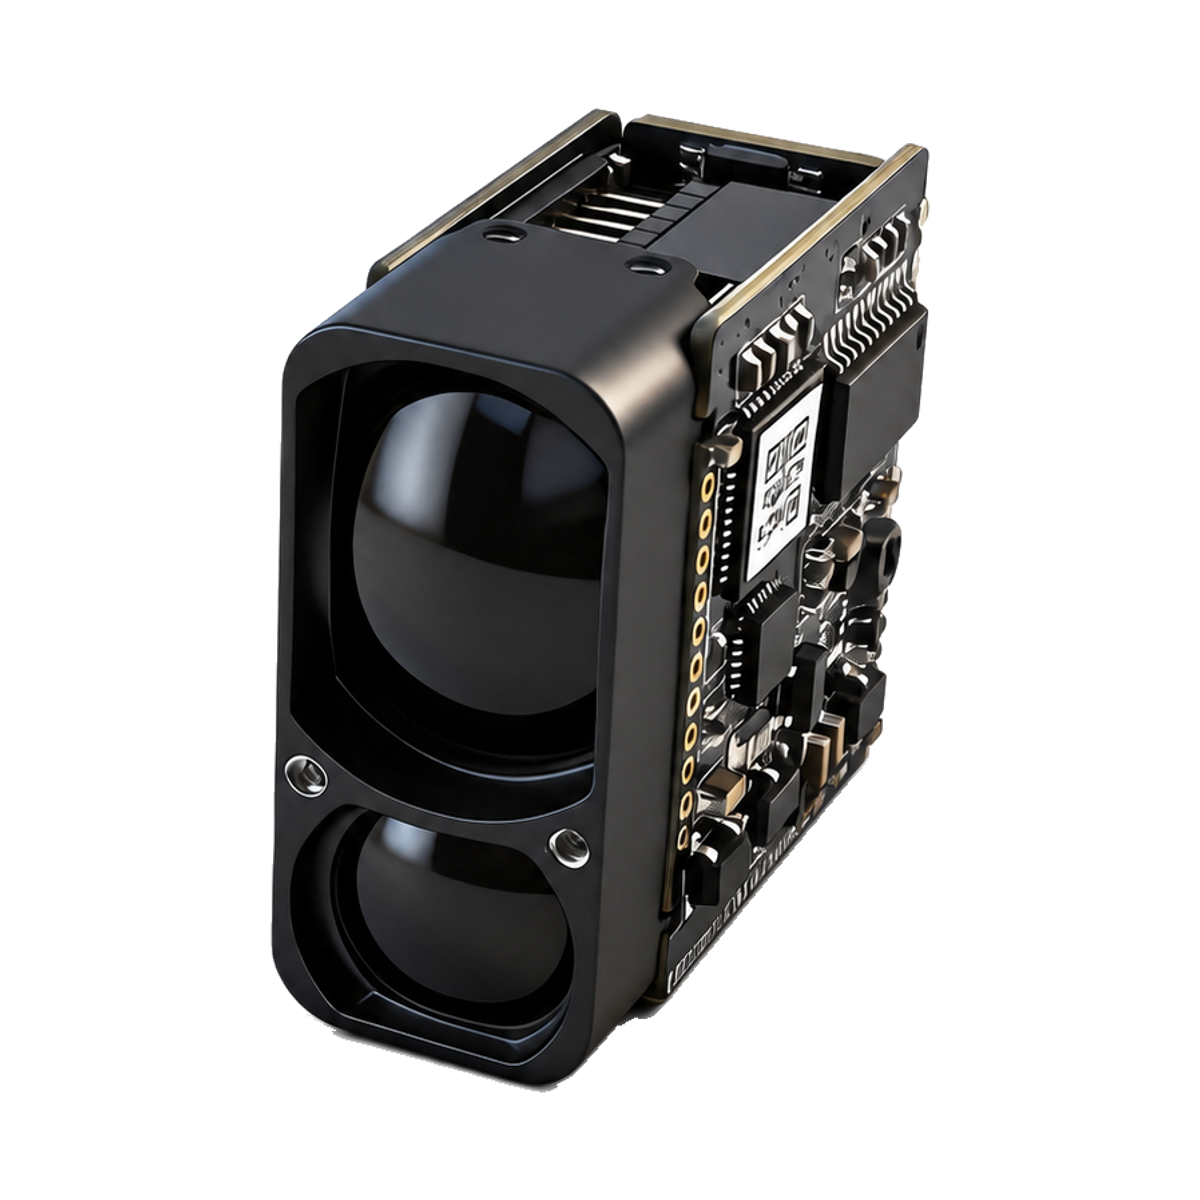
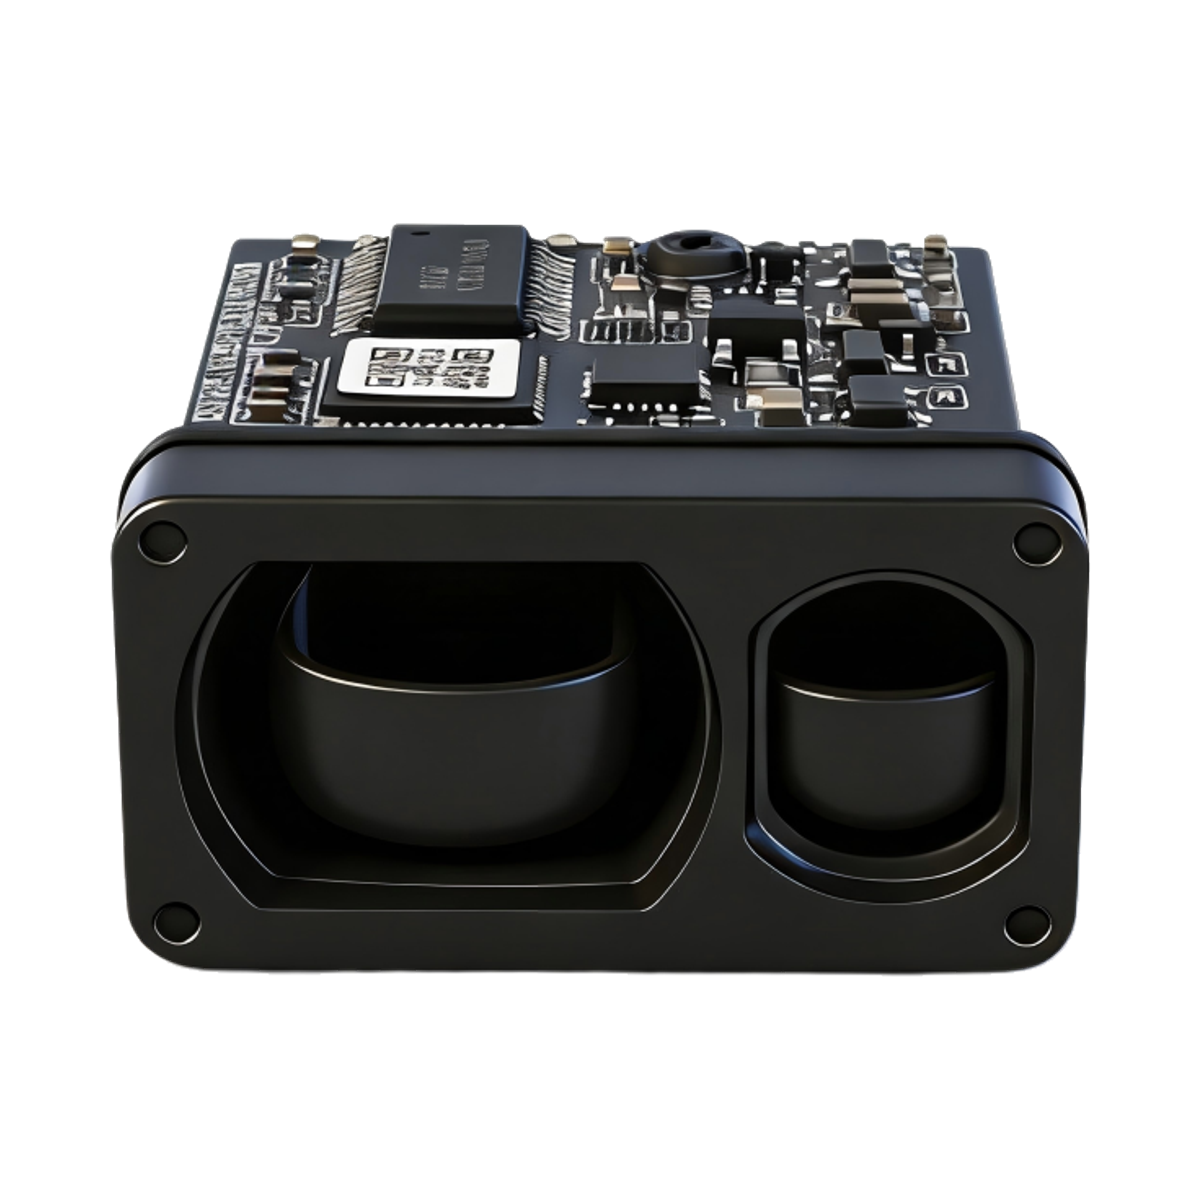
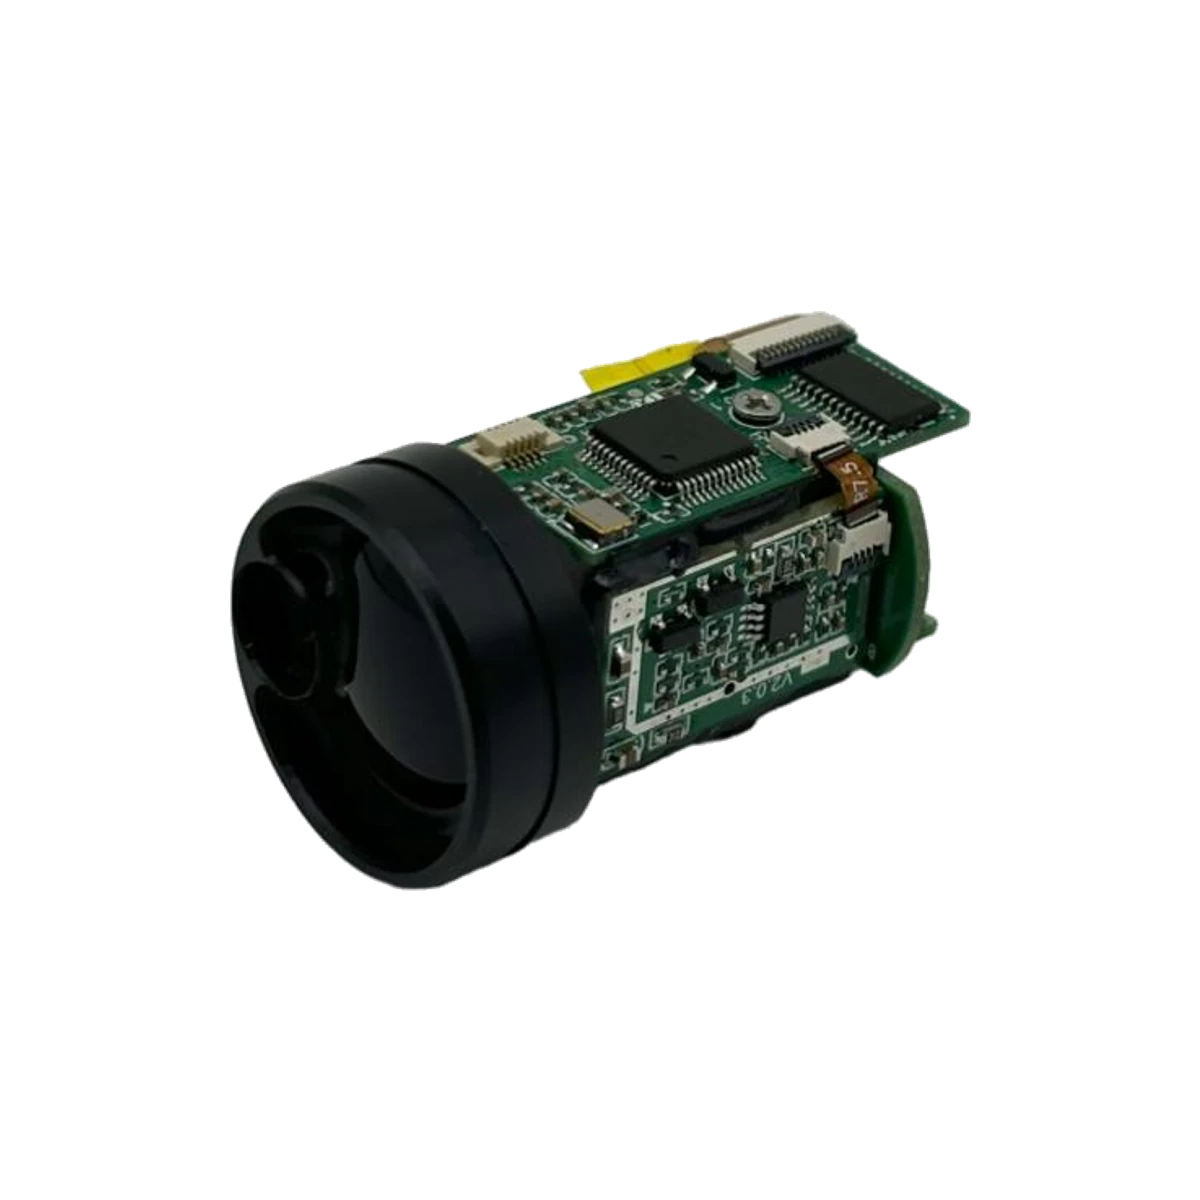
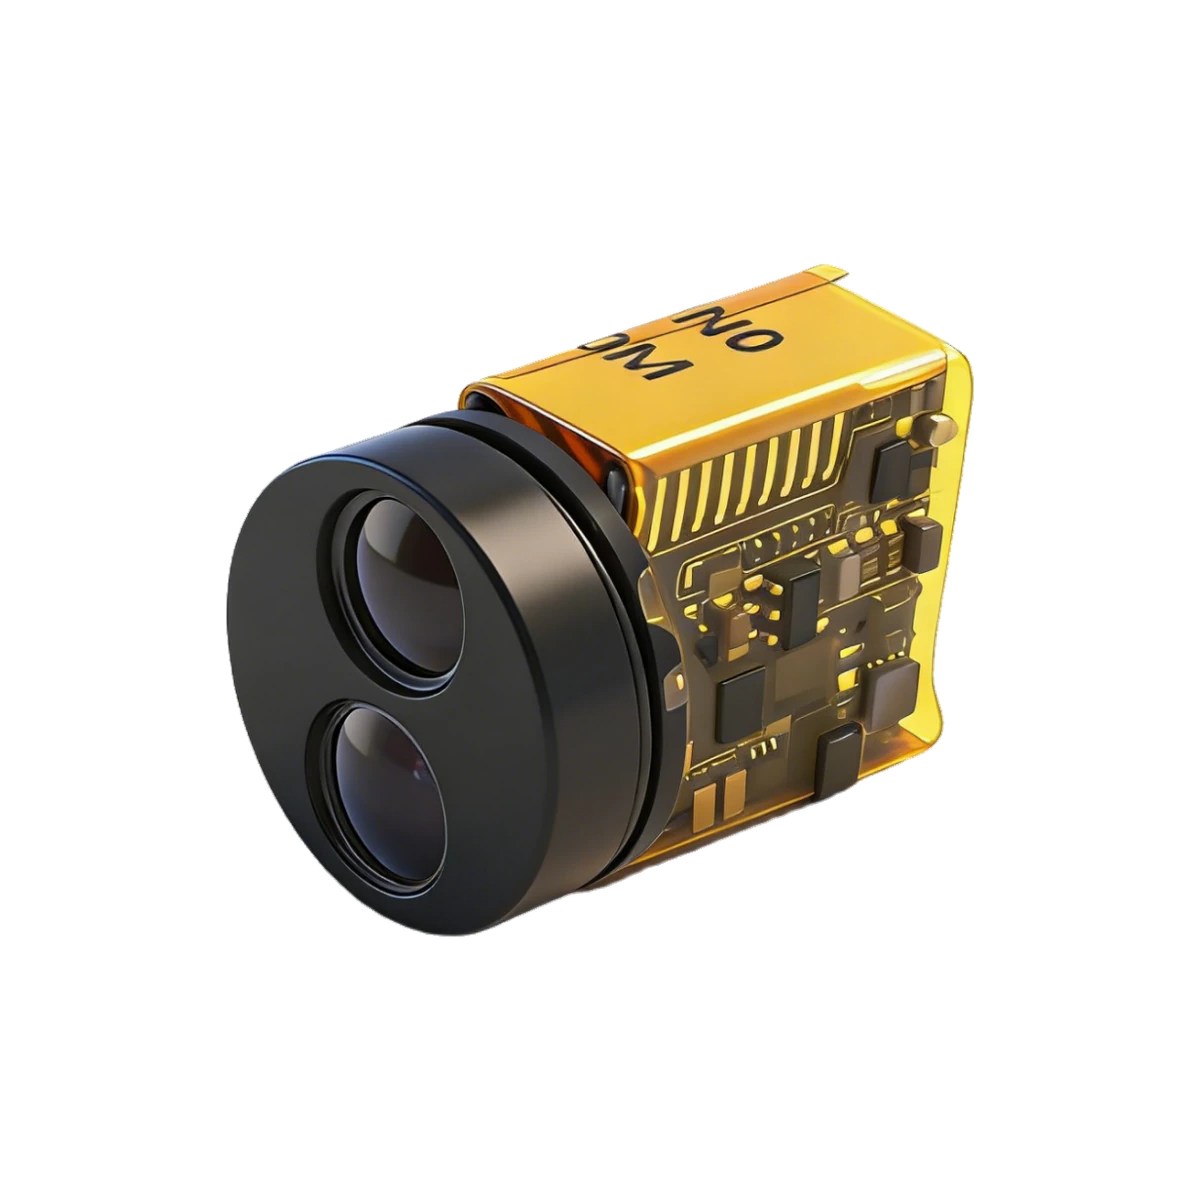
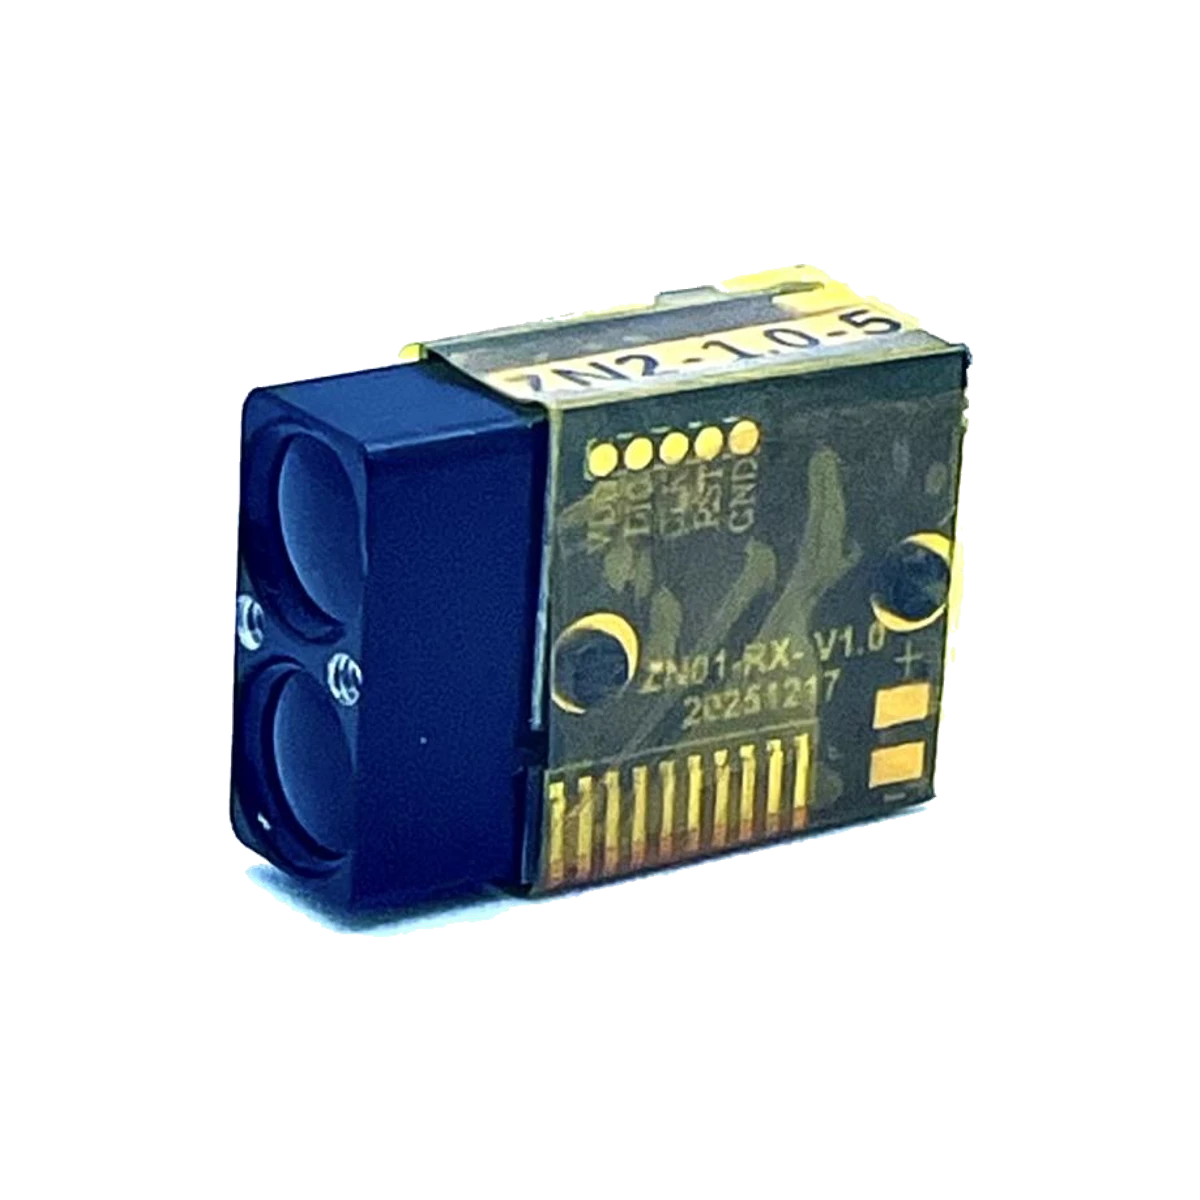
Authentic product views from the ERDI product record. Use the controlled mechanical drawing and connector definition for design release.
Open dedicated 3D viewerOEM laser ranging and photonics module
Product model SPD1200ZG
Compact 0.1–1200 m pulsed time-of-flight ranging with SPAD-based single-photon reception, configurable inertial angle reporting, and relative 3D point-to-point measurement.
Use the current controlled document revision for design review and confirm the ordered connector and mechanical configuration before release.
Published unit prices apply only to the stated quantity band. Configuration, qualification, tax and Incoterm details are confirmed in the quotation.
The SPD1200ZG combines compact 905 nm pulsed laser ranging with integrated inertial angle sensing for OEM systems that need distance, attitude, and relative three-dimensional point-to-point measurement in one lightweight module.
It supports single and continuous ranging, configurable angle reporting, and UART-TTL communication for host integration.
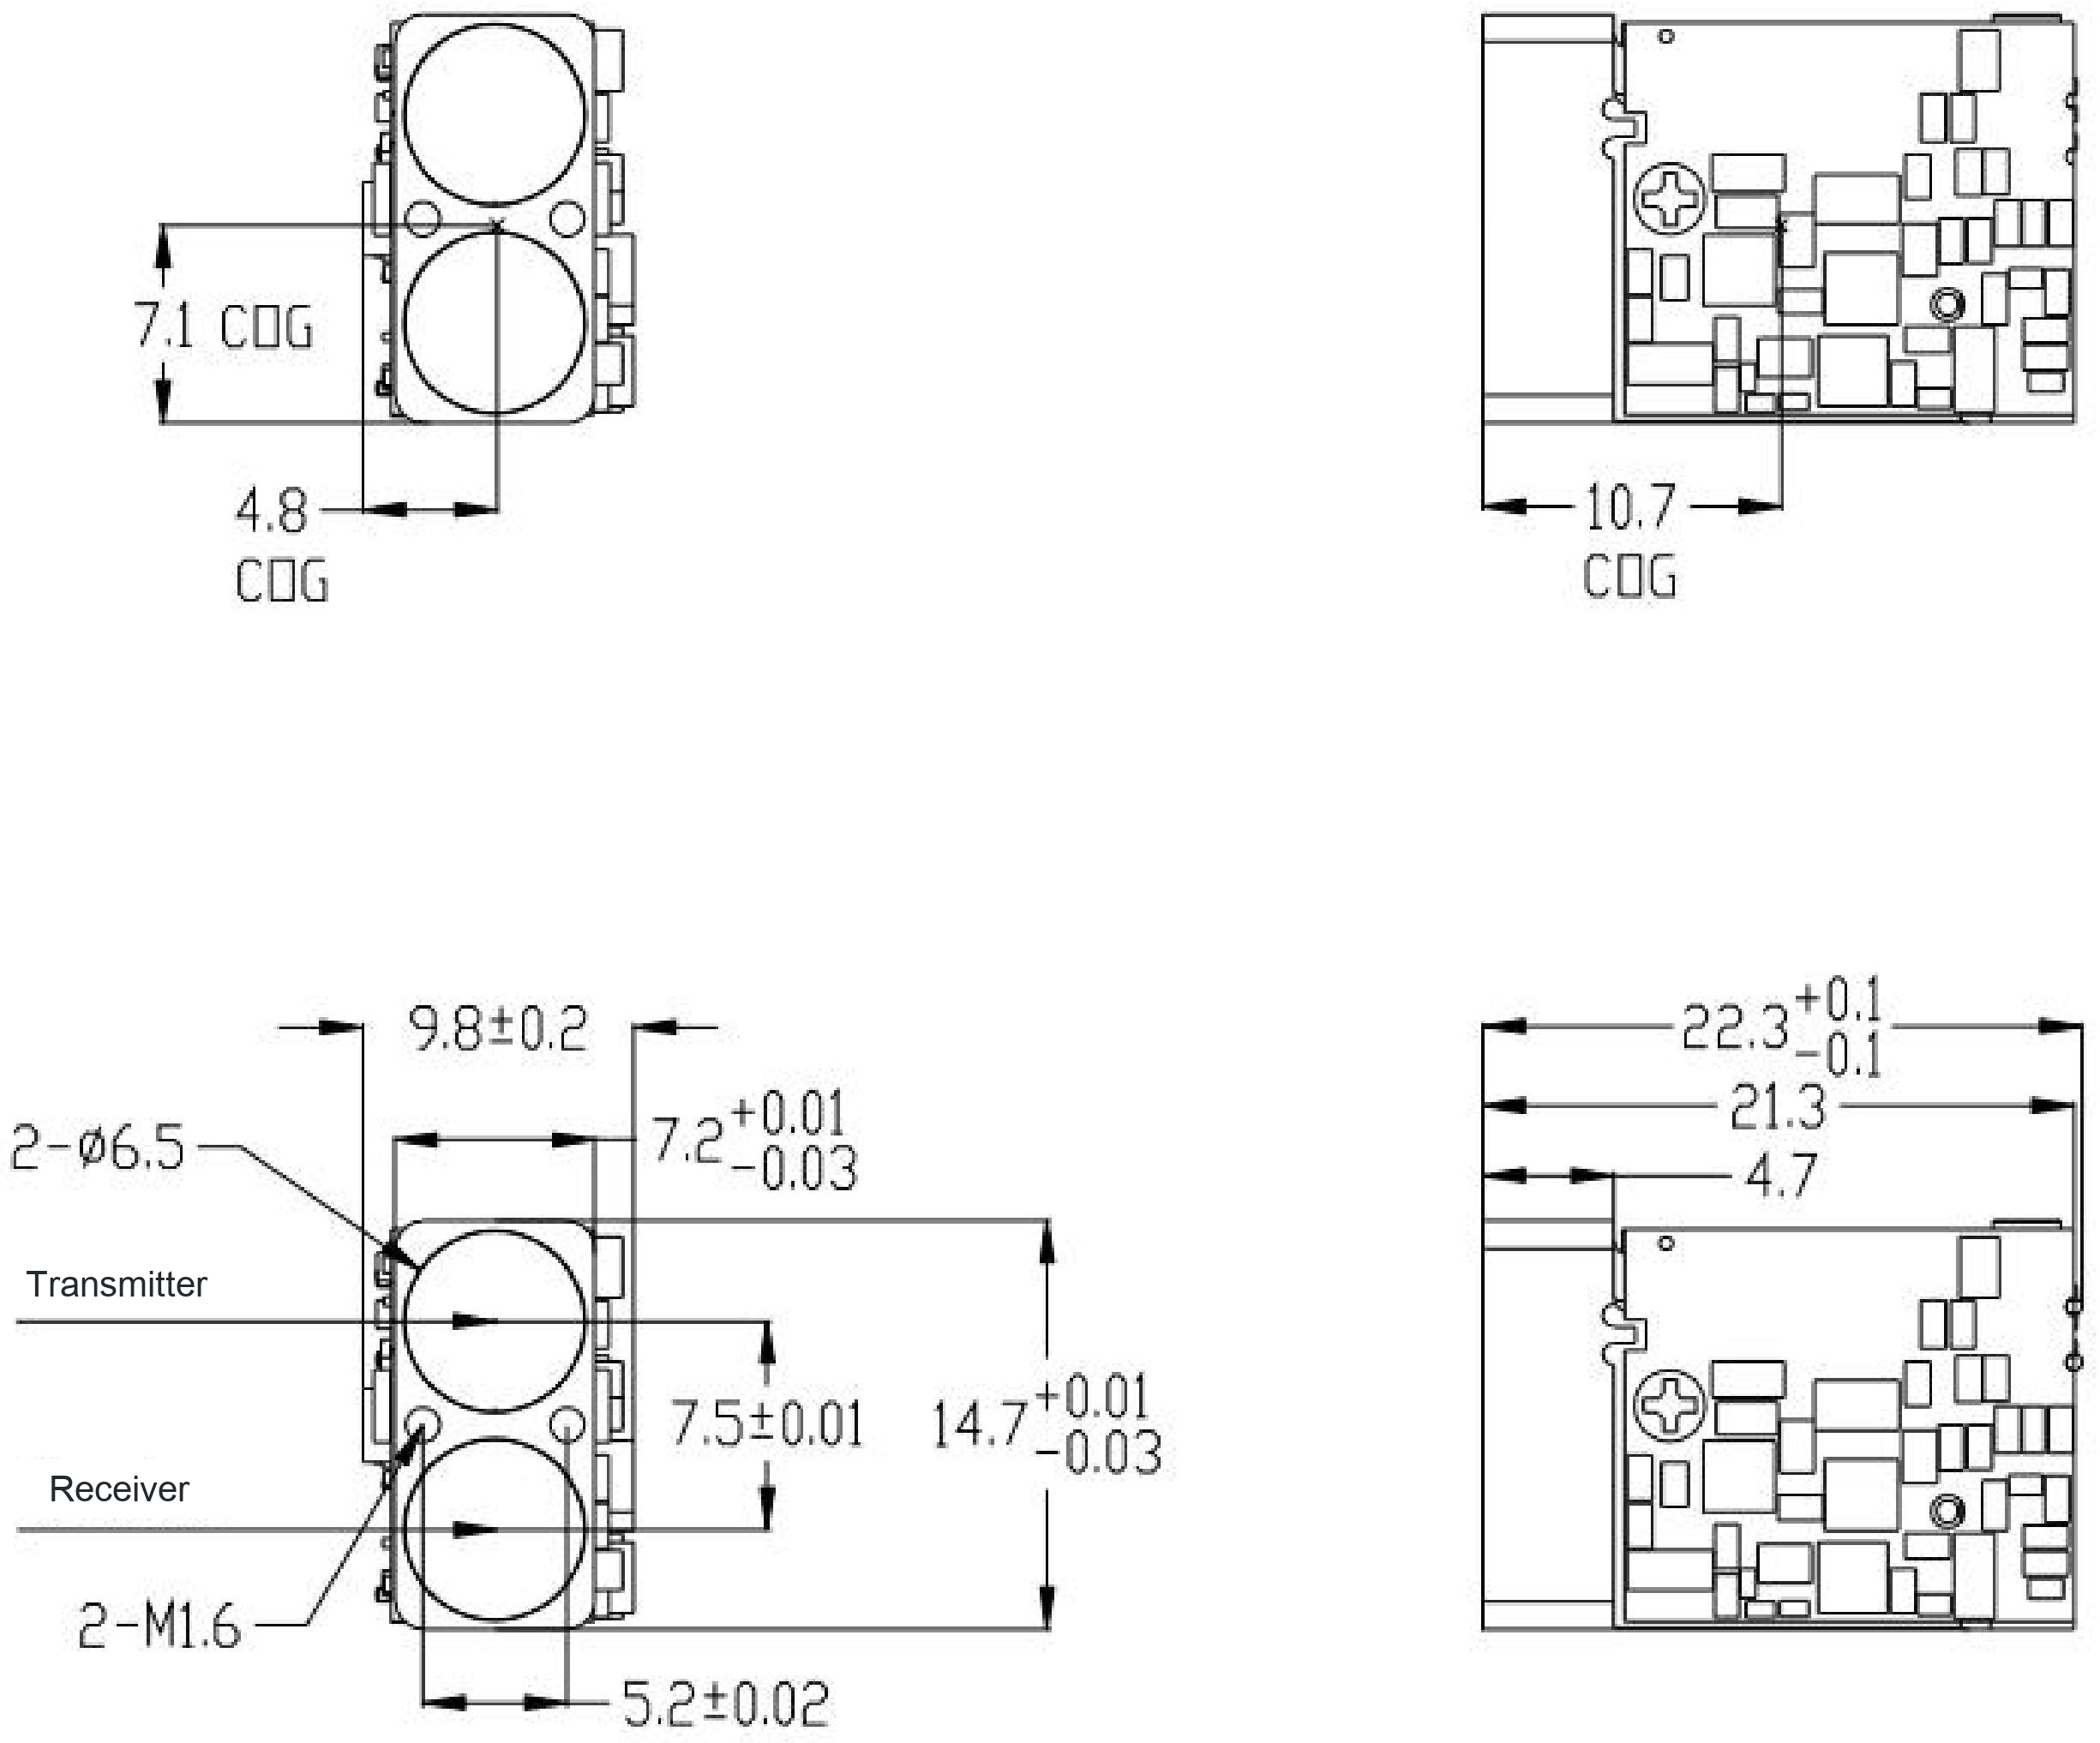
Nominal body dimensions are 7.2 × 14.7 × 22.3 mm and weight is no more than 5 g; the complete installation envelope is governed by the current mechanical drawing.
905 ± 5 nm direct time-of-flight ranging with single-photon reception for weak optical returns.
Rated with visibility ≥10 km, humidity ≤60%, and a building target.
Configurable roll, pitch, and relative yaw/heading reporting for angle-enabled builds.
Combines local range and angle information for target-point coordinates and spatial separation.
Nominal body size 7.2 × 14.7 × 22.3 mm, 6061 aluminum-alloy housing, and weight ≤5 g.
UART-TTL communication, 115200 bps default baud rate, and a 2–10 Hz measurement update rate.
Read each performance value with its stated target, environmental, operating, and installation conditions.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Laser wavelength | 905 ± 5 nm | — |
| Beam divergence | <6 mrad; small beam spot | — |
| Optical element | Aspheric lens | — |
| Receiver aperture | Ø6.5 mm | — |
| Measurement range | 0.1–1200 m | Visibility ≥10 km; humidity ≤60%; building target |
| Ranging accuracy | ±0.5 m at d ≤100 m; ±(0.5 m + 0.0007d) for 100 m < d <1200 m | — |
| Measurement update rate | 2–10 Hz | — |
| Measurement success rate | ≥98% | — |
| False alarm rate | ≤1% | — |
| Laser safety class | IEC Class 1 | — |
| Parameter | Value | Conditions / notes |
|---|---|---|
| Communication interface | UART-TTL; customizable | — |
| Default baud rate | 115200 bps | — |
| Supply voltage | 3.3–5 V | — |
| Startup time | ≤200 ms | — |
| Peak startup current | ≤200 mA | — |
| Standby power consumption | ≤0.3 W | — |
| Average power consumption | ≤0.7 W | — |
| Operating temperature | −20 to +60 °C | — |
| Storage temperature | −30 to +70 °C | — |
| Ingress protection | IP67 within the lens cavity | — |
| Parameter | Value | Conditions / notes |
|---|---|---|
| Nominal module body | 7.2 × 14.7 × 22.3 mm; rectangular | The complete installation envelope includes protruding features; use the current mechanical drawing. |
| Housing material | 6061 aluminum alloy | — |
| Weight | ≤5 g | — |
| Width across protruding features shown in drawing | 9.8 ± 0.2 mm | — |
| Core width shown in drawing | 7.2 +0.01/−0.03 mm | — |
| Height shown in drawing | 14.7 +0.01/−0.03 mm | — |
| Axial dimensions shown in drawing | 22.3 ± 0.1 mm and 21.3 mm | — |
| Mounting features shown in drawing | 2 × M1.6; 5.2 ± 0.02 mm spacing feature | — |
| Optical features shown in drawing | 2 × Ø6.5; 7.5 ± 0.01 mm spacing feature | — |
| Center-of-gravity coordinates shown in drawing | 7.1, 4.8, 10.7 | — |
| Parameter | Value | Conditions / notes |
|---|---|---|
| Roll range, X axis | ±180° | — |
| Pitch range, Y axis | ±90° | — |
| Yaw range, Z axis | ±180° | — |
| X/Y tilt accuracy | 0.3° | — |
| Z-axis heading accuracy | ≤0.75° within a 10 s dynamic measurement interval | Integration error accumulates during motion; this is relative heading, not an absolute north reference. |
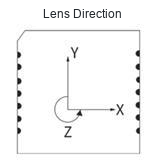
| Axis orientation | Y axis points toward the lenses | — |
| Parameter | Value | Conditions / notes |
|---|---|---|
| d ≤500 m | ±1 m | Distance variable d follows the product specification. |
| 500 m < d <1200 m | ±(1 m + 0.001d) | Distance variable d follows the product specification. |
| Parameter | Value | Conditions / notes |
|---|---|---|
| <100 m | ≤1 m | — |
| 100–500 m | ≤3 m | — |
| 500–1000 m | ≤5 m | — |
| Parameter | Value | Conditions / notes |
|---|---|---|
| <50 m | ≤1 m | — |
| 50–100 m | ≤3 m | — |
| 100–500 m | ≤6 m | — |
| 500–1000 m | ≤10 m | — |
The module transmits a short optical pulse and detects light reflected from the target. If the measured round-trip transit time is Δt, the geometric one-way range is R = cΔt / 2. The factor of two accounts for the outbound and return paths.
Timing resolution, pulse width, receiver bandwidth, target reflectivity, incidence angle, background illumination, and beam divergence influence practical ranging performance. [1]
This SPD1200ZG configuration uses SPAD-based single-photon reception. A single-photon avalanche diode can register individual photon events.
In direct-ToF systems generally, repeated photon detections may be organized in time bins so that a return concentrated around one delay can be distinguished from background detections. Ambient illumination, detector dead time, pile-up, and finite timing resources are recognized constraints. [2] [3]
The standard customer interface reports processed measurements; it does not claim access to raw photon timing data or a particular internal processing algorithm.
A conventional six-axis IMU comprises three orthogonal gyroscope angular-rate channels and three orthogonal accelerometer specific-force channels. Six-axis describes six sensing channels, not six independent rotational axes. [6]
Angle reporting is configurable and does not imply that the standard customer interface exposes all six raw sensor channels. Available outputs are defined by the configuration-matched interface protocol.
For a fixed single-axis rotation, the conceptual relationship is θ(t) = θ₀ + ∫ω(t)dt. Angular-rate bias and noise create accumulated angle drift. Three-axis attitude estimation requires an appropriate coordinate convention. [5]
| Measurement | Rating |
|---|---|
| Roll | ±180° about the X axis |
| Pitch | ±90° about the Y axis |
| Relative yaw / heading | ±180° about the Z axis |
| X/Y tilt accuracy | 0.3° |
| Z-axis heading accuracy | ≤0.75° within a 10 s dynamic measurement interval |
Integration error accumulates during motion. This is relative heading, not an absolute north-referenced compass specification.
Use the current manual's X/Y/Z convention when interpreting angle-enabled output.
An angle-enabled configuration can acquire range and angular information for point A and point B, then report their relative spatial separation in one local coordinate frame.
Conceptually, straight-line separation follows DAB = ||pB − pA||. Range uncertainty, angular uncertainty, alignment, zeroing, and motion at both observations propagate into the result. [8]
| Distance band | Error |
|---|---|
| d ≤500 m | ±1 m |
| 500 m < d <1200 m | ±(1 m + 0.001d) |
| Distance band | Error |
|---|---|
| <100 m | ≤1 m |
| 100–500 m | ≤3 m |
| 500–1000 m | ≤5 m |
| Distance band | Error |
|---|---|
| <50 m | ≤1 m |
| 50–100 m | ≤3 m |
| 100–500 m | ≤6 m |
| 500–1000 m | ≤10 m |
The nominal 7.2 × 14.7 × 22.3 mm body size does not include every protruding feature. Use the complete drawing and its tolerances for installation.
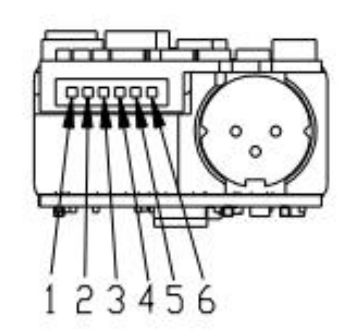
The 3.3–5 V high-level range applies to the SW-SHOT input. It is not a blanket voltage rating for the UART pins.
| Pin | Signal | Function |
|---|---|---|
| 1 | GND | Power-supply ground |
| 2 | VCC | Positive supply input |
| 3 | IO (reserved) | Reserved for expansion |
| 4 | TXD | Module-to-host signal output |
| 5 | RXD | Host-to-module signal input |
| 6 | SW-SHOT | Function enable, active high; high-level input range 3.3–5 V |
Initiates one target-distance measurement. For a low-reflectivity target, the module automatically repeats the measurement until it obtains a stable reading, then reports the result through the serial interface.
Repeated distance measurement at a 2–10 Hz measurement update rate.
Angle-enabled configurations report pitch, roll, and relative yaw/heading using the matching interface protocol.
Validate the complete system with representative targets, lighting, temperature, motion, mounting, and the final protective window.
The module emits a short pulse centered at 905 ± 5 nm and measures the light's round-trip transit time. Range follows R = cΔt/2, because the pulse travels to the target and back. [1]
A SPAD can register individual photon events, which supports reception of weak optical returns. A published direct-ToF SPAD implementation demonstrates how repeated arrival-time events can be accumulated in time bins for range estimation under varying reflectivity and background conditions. [3]
No. The 1200 m rating uses visibility ≥10 km, humidity ≤60%, and a building target. Target reflectivity, target size within the beam footprint, incidence angle, haze, rain, dust, and strong background illumination can change practical measurement margin. [1] [4]
For line-of-sight range d in meters, accuracy is ±0.5 m at d ≤100 m and ±(0.5 m + 0.0007d) for 100 m < d <1200 m. This is separate from resolution, repeatability, and 3D point-to-point error.
The receiver must separate returned signal events from background events and detector noise. Bright ambient light increases unrelated detections, while low reflectivity reduces the desired return, lowering signal-to-background ratio. [2] [4]
A conventional six-axis IMU has three orthogonal gyroscope angular-rate channels and three orthogonal accelerometer specific-force channels; it does not mean six independent rotation axes. In an angle-enabled configuration, the module adds roll, pitch, and relative yaw/heading information to the range measurement. The standard interface does not necessarily expose all six raw channels. [6]
No. It is a relative inertial heading/yaw measurement. The specified accuracy is ≤0.75° within a 10 s dynamic measurement interval, and integration error accumulates during motion. [5]
The specified X/Y tilt-accuracy value is 0.3°. Gravity/acceleration-derived tilt is most reliable under static or quasi-static conditions, while dynamic acceleration can affect inferred tilt. Validate the module in the intended motion profile and mounting arrangement. [7]
An angle-enabled configuration acquires range and angle information for both points in one local coordinate frame, then reports their straight-line spatial separation. In general geometry, this is the Euclidean distance between the two point vectors. [8]
Line-of-sight range is one scalar measurement. A point-to-point result combines two observations and their angular estimates, so range error, angle error, alignment, zeroing, and motion all contribute. [8]
The module supports UART-TTL and a 2–10 Hz measurement update rate. The default baud rate is 115200 bps, interface customization is available, and the supply range is 3.3–5 V.
Use the interface protocol supplied for the ordered firmware and configuration. The matching document defines the applicable packet fields, value scaling, and checksum handling for host implementation.
The current SPD1200ZG manual defines product specifications. The independent references explain general principles and do not replace the module's stated ratings or conditions.
Technical inquiry
Share the target, range, interface and expected quantity. Your selected model stays attached to the inquiry.
Same series
Open a nearby model to compare range, SWaP and interface choices.